1
Rulebook
Description and objective, team composition, format and progression, run structure and timings, permitted and prohibited actions, penalties, appeals, and definitions.
Events / Build-Different
The Doon School · 08–10 December 2026
Stage Three is revealed only once qualification has ended. It requires no hardware change to the robot, but reprogramming between runs is permitted with your own laptop. Build for adaptability.
Tele-Operated Robotics
Rules
Withheld content. Stage Three is revealed in writing to the four semi-finalists once qualification ends. It requires no hardware change.
Event details
Judging
Judging rubric
| Criterion | Weight | Marks |
|---|---|---|
| Plant colour-matching | 40 | |
| Monument placement | 30 | |
| Monument configuration | 20 | |
| Driver precision | 10 | |
| Total | 100 |
Weights are those in the event’s published documents. Scoring levels, tie-break order and who scores what are set out in full in the document pack below.
Documents
5 of 6 documents available
These are the documents your team will receive for Build-Different. Between them they set out everything a team needs in order to prepare.
1
Rulebook
Description and objective, team composition, format and progression, run structure and timings, permitted and prohibited actions, penalties, appeals, and definitions.
2
Robot Specification
Dimensions at start and expanded, mass, power source and voltage limits, permitted actuators and sensors, control method, communication protocol, prohibited materials.
3
Arena Specification
A dimensioned scale drawing in plan view, all fixed dimensions with tolerances, surface material and finish, wall heights, printable colour references, and the exact range of any variation between rounds.
A school must be able to build a practice replica from this document alone.
4
Judging Rubric
Criteria with point values summing to a stated total, scoring levels, tie-break order, who scores what, and when scores are published.
5
Inspection & Safety
Pre-competition inspection checklist and schedule, consequences of failed inspection, safety requirements during runs, spectator boundaries, and the emergency stop procedure.
6
Support Material
A worked example, a starter guide to core techniques, the concepts a team should learn, common mistakes, and an FAQ.
Documents marked “Available soon” will appear here as soon as they are released.
Flow
The event from start to finish, as the rules above set it out. The detailed documents for Build-Different will appear here once they are released to registered schools.
60-second setup, robot in the starting zone
Start signal
Up to 300 seconds, driven by line of sight from one handheld controller.
Stage One: plants
Place each of the four plants in the pot of the matching colour.
Stage Two: monument
Carry the five pieces up a ramp and assemble them on the central platform in the prescribed configuration.
Driver declares completion
Arena scored as it stands; elapsed time recorded for tie-breaks.
Top 4 on best qualification run?
If yes, continue to the next step.
If no: Event ends for the team
Semi-finals and final: a run, then Stage Three
Revealed once qualification ends. No hardware change.
Higher match total wins
Who runs it
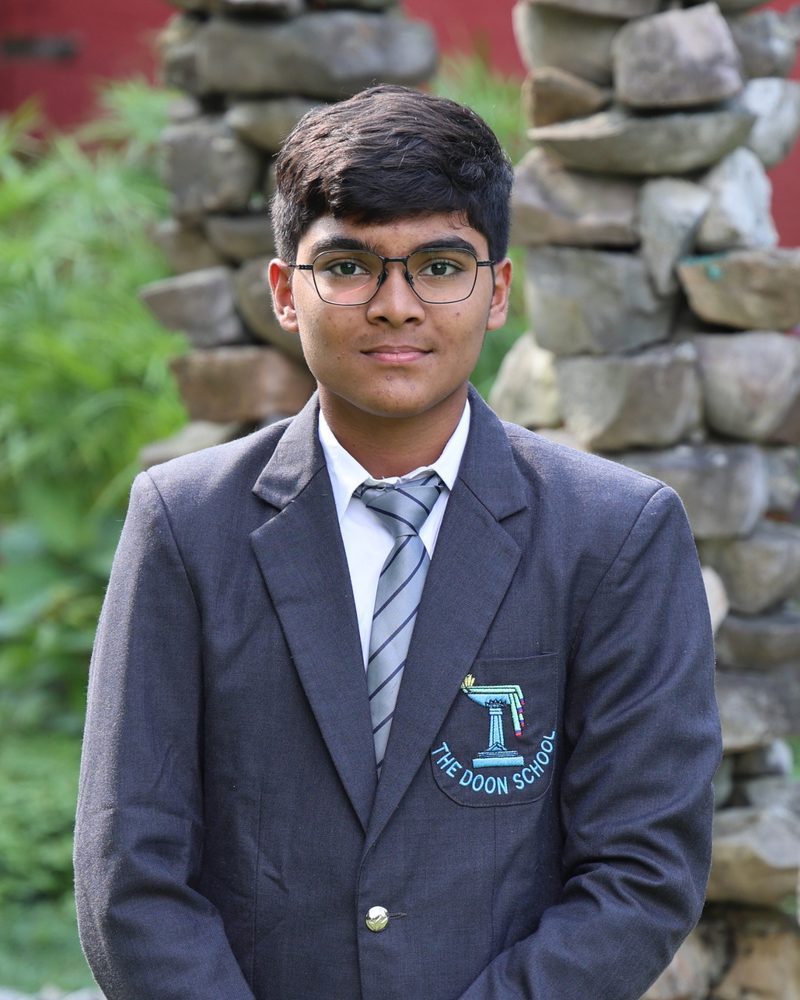
Arnav Kharpude
Event Head
Arnav is a student at The Doon School pursuing the IB Diploma Programme, with a keen interest in Robotics, Science and Engineering. He has worked on robotics and computer-vision projects using ESP32, Raspberry Pi and OpenCV, and also explores genetics and biotechnology. An avid sportsman, he plays hockey, football and tennis. He is also an enthusiastic reader, with a particular fascination for psychology and philosophy. In his free time, he enjoys watching Formula One. He is honoured to serve as the Event Head of Build-Different at the IPSC IT Fest 2026.
Deputy Event Heads
Dhrubo Mishra
Yug Jain
Next
Remote-controlled robots push each other into the red band at the edge of a ring, scoring for every second the opponent spends there.